Rig
- ≈ €1,350owned hardware (paid; 3 small parts not priced yet)
- $45rented GPU and API for the 22 register tests
- simmost common setup behind the papers' own claims (9 of 22; 10 on rigs over $5k)
Parts
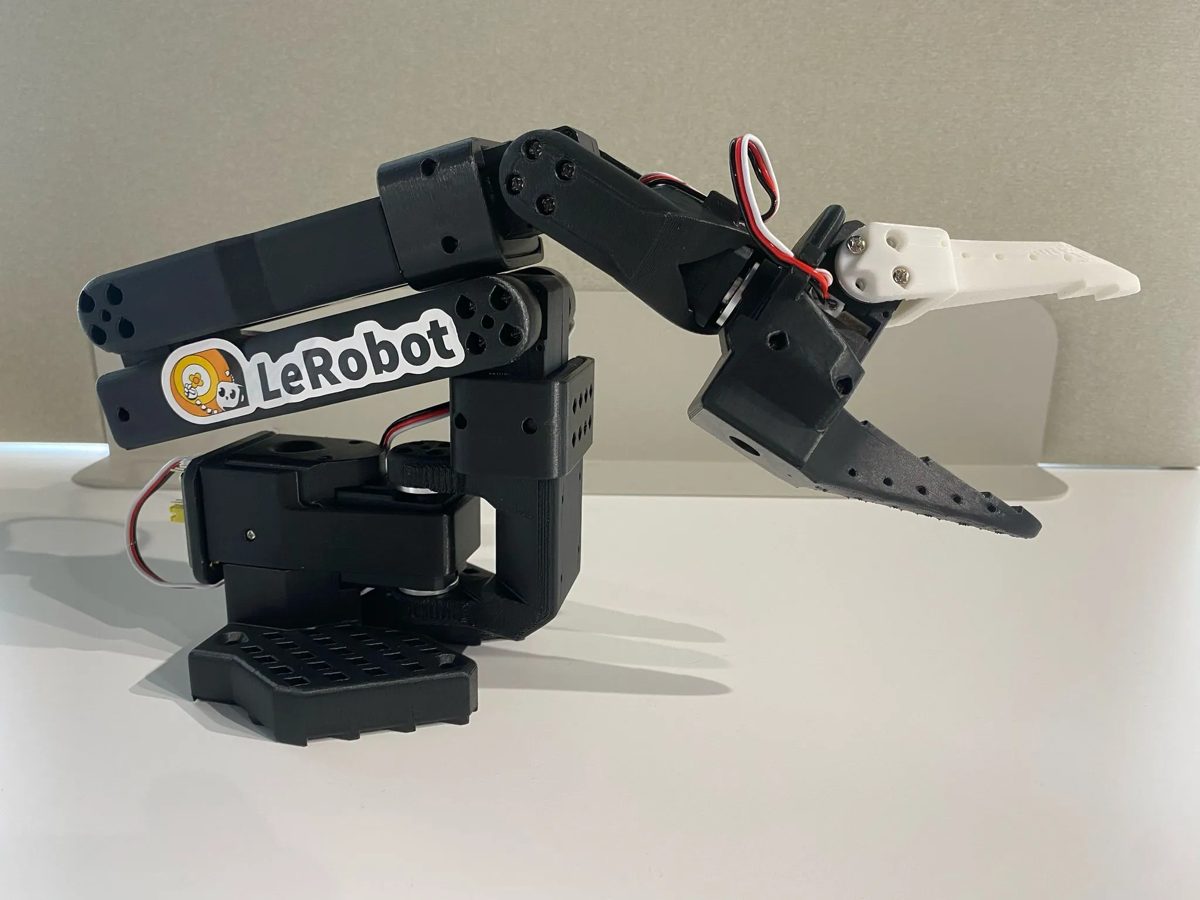
SO-101 follower arm — the arm every trial ran on
- 6 DoF, Feetech STS3215 servos
- position control, no force or torque sensing
- G-clamped to the back edge of the table
€350 paid (pack price, with the leader arm and the wrist camera)
Limits: short reach and no contact sensing: a grasp is only known to have worked by looking
all experiments
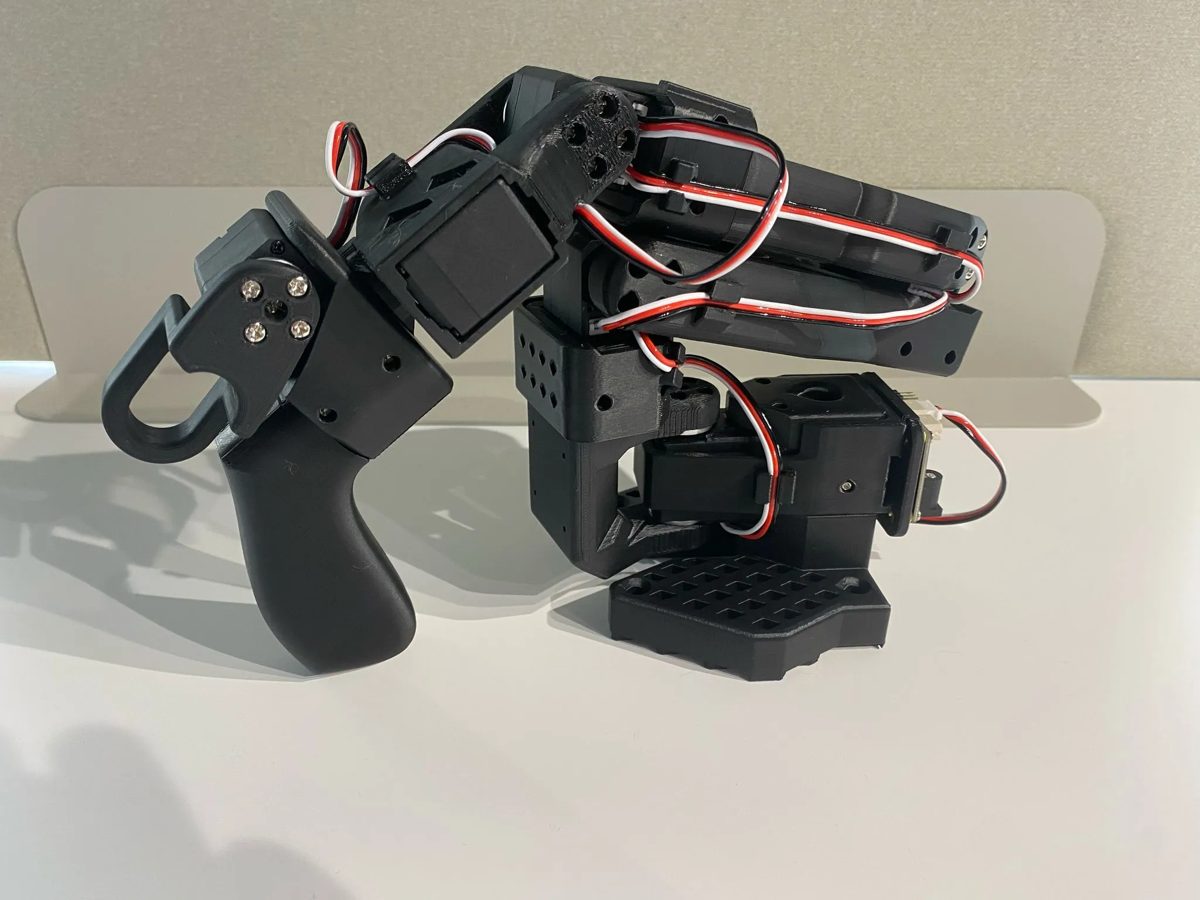
SO-101 leader arm — teleoperation, for recording demonstrations
- same servos, passive gripper handle
- packed away, out only for recording sessions
included with the SO-101 follower arm
Limits: setting up teleop takes time, so new data comes in batches
data
NVIDIA Jetson Orin NX 16 GB (Super dev kit) — the only computer on the robot
- JetPack 6.2 / L4T R36.4.3, CUDA 12.6
- MAXN_SUPER + jetson_clocks for benchmarks, 25 W otherwise
- headless
€950 paid
Limits: no desktop GPU: models that need flash-attention kernels without an Orin build (REKI) run on a rented GPU
all experiments
Logitech C920 (top camera) — the judge's view and the policy's main view
- 640×480 at 30 fps, OpenCV
- oblique mount; no overhead view possible here
€50 paid
Limits: perspective view lit by a window: colour masks depend on the time of day
all experiments
icSpring USB camera (wrist) — close view of the gripper
- 640×480 at 30 fps, OpenCV
included with the SO-101 follower arm
Limits: narrow field of view; often sees only the bowl it is holding
all experiments
Green cutting mat — work surface
- fixed colour background for the colour masks
price to come
Limits: one surface, one colour: no texture or lighting variation unless added on purpose
all experiments
Folding table — holds the station
- station stays installed; leader packed away
price to come
Limits: moves on contact, so hard pushes shift the camera geometry
all experiments
Clamp, USB hub, power supplies, cables — everything else
- one G-clamp, one USB hub, servo and Orin power supplies
price to come
Limits: a loose USB link drops servo packets (seen on motors 4 and 5)
all experiments


Rented GPUs (vast.ai) — training, and serving models the Orin cannot run. RTX 3090 / 4090, A6000, RTX PRO 5000 class, by the hour · destroyed after each run. Total to date: $45 (scoreboard).
What this rig cannot test
- SO-101 follower arm: short reach and no contact sensing: a grasp is only known to have worked by looking
- SO-101 leader arm: setting up teleop takes time, so new data comes in batches
- NVIDIA Jetson Orin NX 16 GB (Super dev kit): no desktop GPU: models that need flash-attention kernels without an Orin build (REKI) run on a rented GPU
- Logitech C920 (top camera): perspective view lit by a window: colour masks depend on the time of day
- icSpring USB camera (wrist): narrow field of view; often sees only the bowl it is holding
- Green cutting mat: one surface, one colour: no texture or lighting variation unless added on purpose
- Folding table: moves on contact, so hard pushes shift the camera geometry
- Clamp, USB hub, power supplies, cables: a loose USB link drops servo packets (seen on motors 4 and 5)
No force, one arm, no scale; every write-up says which of these applies to it.
Not owned yet
- Second SO-101 (assembled) — a second arm for two-arm tasks status: not owned
- reBot B601-DM — upgrade path if reach becomes the limit status: not owned
- Desktop GPU, Jetson Thor or DGX Spark — considered for on-site training and for models with no Orin build status: not owned
Photo credits
- SO-101 follower arm: source, Apache-2.0 (TheRobotStudio/SO-ARM100)
- SO-101 leader arm: source, Apache-2.0 (TheRobotStudio/SO-ARM100)


Rig profile and calibration shape: paper-vs-hardware/rig/. Prices marked paid are what I paid, in euros; the source of every price is in data/rig.yaml, and none is a guess.
Reproducibility
Every post's numbers were recomputed cold on 2026-10-31, from a fresh clone of the public repository, the public Hub
with no token and the published container, on this Orin NX at 25 W: bars recomputed from the published rows on 29 of
29 posts, gates rerun on the Orin for 6, none contradicted. The table, the versions and the tolerance rule:
paper-vs-hardware rig/REPRODUCIBILITY.md.